ROSCon Global 2026
September 22 - September 24
🤖 Celebrating Community and Open-Source Collaboration at ROSCon 2026! 🚀
The heart of robotics doesn’t just lie in the hardware, it beats within the global developer community that brings these machines to life. That is why PAL Robotics is incredibly thrilled to participate in ROSCon 2026! As long-standing champions of open-source robotics, this event is, for us, the ultimate celebration of shared knowledge, collaboration, and collective innovation.
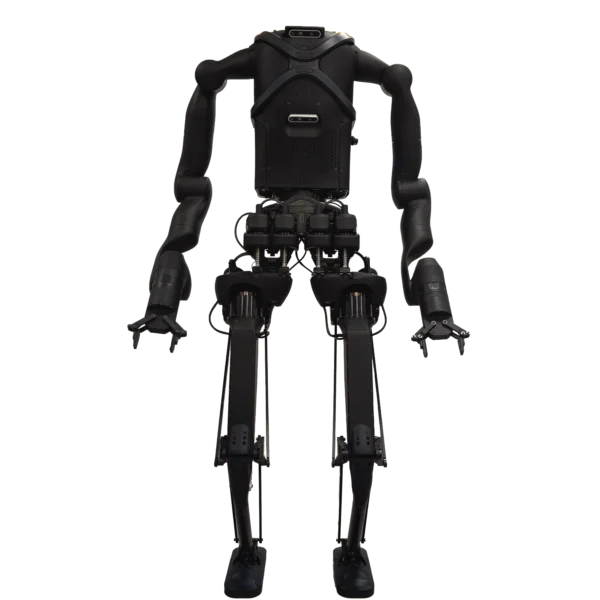
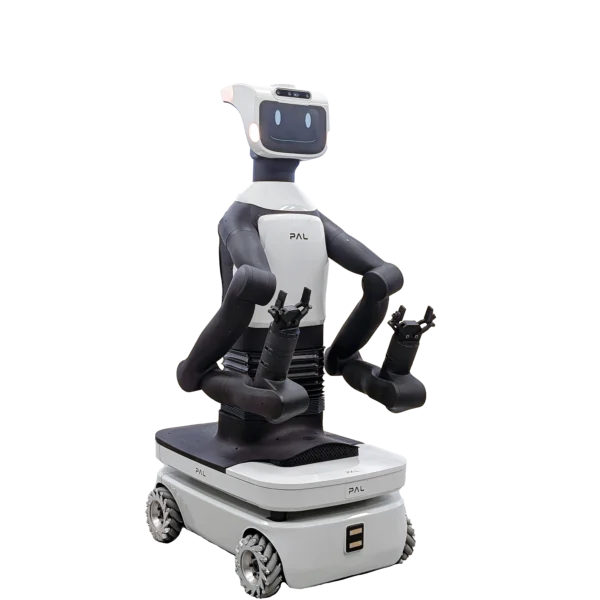
Our core motivation has always been to empower researchers, developers, and enthusiasts worldwide. By building our advanced platforms, like the TIAGo Pro mobile manipulator and our humanoid robots, on an open ROS 2-based architecture, we ensure that the global community has the flexible, reliable tools needed to push the boundaries of what’s possible.
We can’t wait to connect with fellow ROS developers, exchange ideas, share our latest integration insights, and learn from the incredible projects being built by this global ecosystem. Together, we aren’t just writing code—we are shaping the collaborative future of robotics.
Our Agenda
This year, Sai Kishor Kothakota, Robotics Engineer at PAL Robotics, will contribute to three sessions exploring key developments across the ROS 2 ecosystem, from ros2_control and reinforcement learning to high-fidelity simulation and URDF.
Scaling ros2_control: From Async Hardware Drivers to RL Inference Engines
September 22 | 1:00 pm – 5:00 pm
This hands-on workshop explores how to build production-ready ros2_control systems beyond synchronous architectures. Participants will learn how to design asynchronous hardware interfaces, reduce I/O bottlenecks and deploy reinforcement learning policies using ONNX and Torch as non-blocking controllers.
The session will also cover thread-safe data exchange, inference jitter, driver-controller synchronization and real-time stability, showing how ros2_control can support both production robotics systems and RL deployment on real hardware.
mujoco_ros2_control: High Fidelity Physics Simulator for ROS
September 23 | 1:50 pm – 2:10 pm | Grand Ballroom East
This session introduces mujoco_ros2_control, a system interface that brings MuJoCo’s high-fidelity physics simulation into the ros2_control ecosystem.
It will explore capabilities including URDF-to-MJCF conversion, real-time sensor streaming to RViz2, ros2_control plugins and support for complex mechanisms such as tendons and mimic joints, as well as faster-than-real-time simulation for CI/CD testing and validation.
Evolution of the Standard: What’s New in URDF 1.2
September 23 | 2:50 pm – 3:00 pm | Grand Ballroom East
This talk looks at the evolution of the URDF standard and the introduction of URDF 1.1 and 1.2.
It will cover the versioning strategy behind the specification and some of its most requested additions, including quaternion-based orientation, capsule geometry and extended joint limits for acceleration, deceleration and jerk.
💡 Let’s keep building, learning, and growing together! See you at ROSCon 2026!
OUR ROBOTS